Lenze EVS9325-EPV004 EVS9325-EP – 5.5kW 9300 Servo Position Controller


Het item werd toegevoegd aan uw offerteaanvraag
Product Information
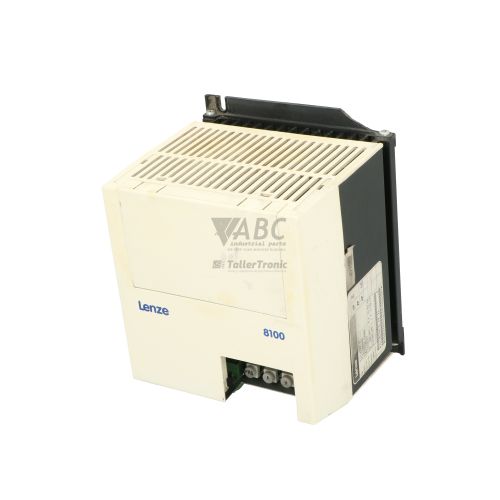
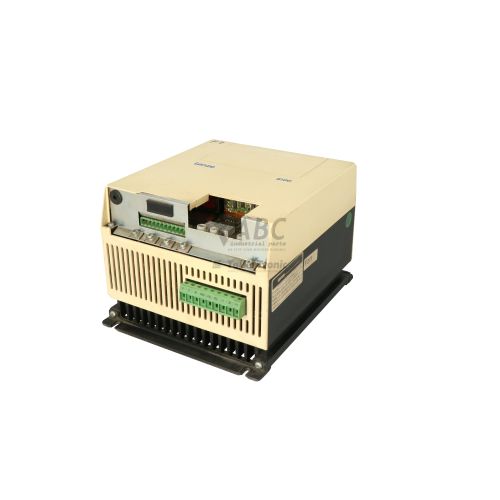
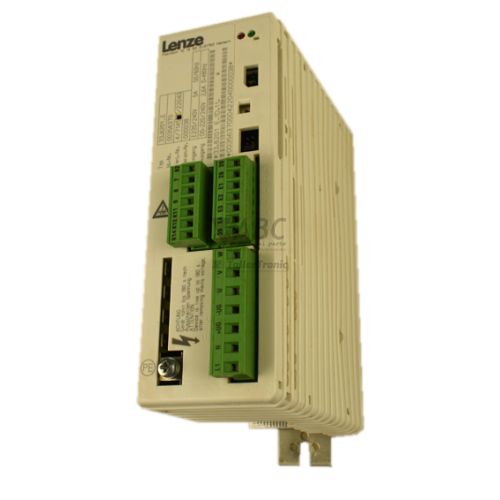
The Lenze EVS9325-EPV004 is a 5.5 kW servo position controller from the Lenze 9300 Servo series, designated under model code EVS9325-EP. Operating on a 3-phase line supply from 320 V AC to 528 V AC, this unit combines inverter power electronics, motion feedback processing, and position control into a panel-mounted housing. It provides 13 A of continuous output current with a peak current capacity of 19.5 A and a maximum output frequency of 480 Hz at an 8 kHz switching frequency, making it suitable for field-oriented vector control of both synchronous and asynchronous AC servo motors.
For machine integration and control interfacing, the unit provides five digital inputs, three digital outputs, two bipolar analog inputs (-10V to +10V), and two analog outputs (0V to +10V). Dedicated Sub-D connectors support resolver feedback, master frequency inputs, and encoder emulation output, while an onboard CAN system bus operating up to 500 kbit/s supports rapid inter-drive axis synchronization. Module expansion slots accommodate optional fieldbus interfaces, including the EMF2133IB PROFIBUS-DP card and EMF2175IB CANopen or DeviceNet cards. Commissioning a replacement unit requires restoring parameter sets to non-volatile EEPROM storage, which can be accomplished using the Keypad XT (EMZ9371BC) or Lenze Global Drive Control (GDC) software, with parameter extraction support available through ABC Industrial Parts when swapping components on active lines.
System status and internal health are monitored via two front-panel LED indicators—a red TRIP LED and a green Operation LED—along with internal diagnostic code registers C0003, C0161–C0168, and C0170. Detailed fault messages such as short circuit (OC1), earth fault (OC2), overvoltage (OU), or hardware component failure (H05) are displayed directly on the Keypad XT or within GDC software. First-line troubleshooting involves checking line voltage, thermal sensor wiring on terminals X10/T1 and T2, motor phase insulation, and CAN bus termination resistors (120 Ohm). Where internal power module failures or EEPROM corruption (EER) occur, internal component repairs are not field-serviceable, and sourcing a tested replacement drive from ABC Industrial Parts offers a direct path to minimizing downtime.
Technical Specifications
| Manufacturer | Lenze |
| Part Number | EVS9325-EPV004 |
| Model / Type | EVS9325-EP |
| Product Family | 9300 Servo |
| Component Type | Servo Position Controller |
| Rated Power | 5.5 kW |
| Supply Voltage Range | 320 - 528 V AC |
| Rated Current | 13 A |
| Peak Output Current | 19.5 A |
| Control Method | Vector Control / Field-Oriented Control |
| Maximum Output Frequency | 480 Hz |
| Switching Frequency | 8 kHz |
| Digital Inputs | 5 |
| Digital Outputs | 3 |
| Analog Inputs | 2 (-10V to +10V) |
| Analog Outputs | 2 (0V to +10V) |
| Integrated Bus | CAN System Bus |
| Max CAN Bus Speed | 500 kbit/s |
Programming and Configuration
Parameterization and motion task setup on the Lenze EVS9325-EPV004 are executed through Lenze Global Drive Control (GDC) PC software or locally using the plug-in Keypad XT (EMZ9371BC). The controller relies on non-volatile EEPROM memory to store system configurations, motor parameters, and motion positioning routines. When replacing an existing controller, parameter sets must be transferred to ensure axis scaling, speed limits, and control loop gains match the machine application.
To complete a parameter transfer via Keypad XT, copy the active parameter set from the existing drive into the keypad memory, insert the keypad into the replacement unit, and execute a parameter load command. Alternatively, connect a PC using GDC software to upload, save, and download parameter files. If configuration errors occur or a clean setup is required, initiating a factory reset via parameter code C0002 restores default factory settings.
Communication and System Integration
The EVS9325-EPV004 includes an integrated onboard CAN system bus interface capable of communication rates up to 500 kbit/s. This bus allows direct inter-drive coordination, electronic gearing, and cross-communication between multiple 9300 series drives without requiring external bus master controllers. Proper operation of the CAN network requires correct baud rate alignment via code C0351 and 120-ohm bus termination resistors installed at both physical line endpoints.
For higher-level network integration with plant PLCs, the controller features dedicated automation expansion slots. Slot A supports optional communication cards, such as the EMF2133IB PROFIBUS-DP module or the EMF2175IB CANopen and DeviceNet modules. In multi-axis positioning architectures, master frequency inputs and encoder emulation outputs via Sub-D connections facilitate synchronous follower tracking across secondary drives.
Diagnostics and Status Indication
The front panel features two status LEDs that provide visual indication of operational conditions. Additional diagnostic information is accessible through diagnostic registers (C0003, C0161–C0168, C0170) using the Keypad XT module or GDC software.
When a trip fault occurs, the drive disables power output to the motor and logs the specific fault code in internal memory for analysis.
Status LED Indicators
| LED | Color/Status | Meaning |
|---|---|---|
| TRIP | Red - Solid / Flashing | Solid = TRIP active (drive faulted); Flashing = Warning / message pending |
| Operation | Green - Solid / Flashing | Solid = Controller enabled / operating; Flashing = Controller inhibit / ready |
Replacement and Spare Part Considerations
When replacing a Lenze EVS9325-EPV004, confirm that the replacement model matches the 5.5 kW rating, continuous 13 A current capability, and EVS9325-EP hardware configuration. Verify that any optional fieldbus modules installed in Slot A, such as PROFIBUS (EMF2133IB) or CANopen (EMF2175IB), are transferred to the replacement unit prior to power-up.
A replacement controller will not operate the machine correctly with default factory parameters. The parameter set must be transferred from the original unit via Keypad XT (EMZ9371BC) or GDC software. Ensure that feedback connections on Sub-D terminals match original resolver or master frequency wiring, and verify that CAN bus terminating resistors are present if the unit forms an endpoint on the network.
Error Codes & Fault Codes
The following error codes may be displayed during operation or diagnostics:
| Code | Name | Description | Possible Cause | Recommended Action |
|---|---|---|---|---|
| OC1 | Short Circuit | Short circuit at motor output terminals | Short circuit in motor cable or motor winding, ground fault, extreme overload | Check motor and wiring for short circuit / phase contact; check motor inductance. If error occurs immediately without connected motor, internal power module is defective — replace unit. |
| OC2 | Earth Fault | Ground fault detected on output side | Ground fault in motor lead or motor winding, insulation breakdown, excessive cable capacitance | Check motor cable and motor for earth short circuit; check ground connection and shielded cable length. |
| OC5 | Overcurrent Acceleration | Excessive motor output current during acceleration phase | Acceleration time set too short, motor mechanical overload, incorrect motor data | Increase acceleration time ramp; check motor load and mechanical binding; verify motor nameplate data settings. |
| OU | Overvoltage DC Bus | DC bus voltage exceeds upper threshold (>770 V DC) | Excessive regenerative energy during deceleration, deceleration ramp too fast, brake chopper or brake resistor defective/missing | Extend deceleration time ramp; check external brake resistor connection and resistance value; check mains voltage. |
| LU | Undervoltage DC Bus | DC bus voltage below threshold (<430 V DC or <285 V DC) | Line supply voltage too low, phase missing on mains power, transient mains power interruption | Check supply voltage line fuses and mains supply; check input supply wiring. |
| OH | Heatsink Overtemperature | Heatsink temperature exceeds maximum allowed limit (>85°C / >90°C) | Insufficient cooling airflow, ambient temperature too high, cooling fan failure, heatsink clogged | Clean heatsink cooling fins; verify enclosure fan operation; reduce ambient temperature. |
| OH4 | Motor Overtemperature | Motor temperature sensor trip via control terminals X10/T1, T2 | Motor thermal overload, cooling fan failure on motor, broken sensor wire | Allow motor to cool; check mechanical load; check motor PTC/KTY sensor wiring. |
| OH7 | Internal Drive Temperature | Internal air / board temperature limit exceeded | Control cabinet temperature too high, internal fan fault | Improve cabinet ventilation; reduce carrier switching frequency or load. |
| OH8 | Motor Sensor Error | Open circuit or short circuit detected on motor thermal sensor input | Defective temperature sensor, broken connection wire on X10 | Check wiring to motor thermal sensor; measure resistance across thermal sensor leads. |
| LP1 | Mains Phase Failure | Failure of one supply voltage phase detected | Blown main fuse, broken mains phase cable | Check line supply voltage on all 3 input phases; check line fuses. |
| NMAX | Max Speed Exceeded | Actual motor speed exceeds parameter C0011 maximum speed limit | Unstable velocity control loop, external driving load, incorrect encoder resolution setting | Check speed controller tuning gain settings; verify feedback encoder resolution. |
| PER | Program Error | Internal program execution fault | Corrupted internal firmware, invalid internal program task routine execution | Perform factory reset and reload parameter set. Internal hardware/firmware error — if fault persists, return unit for repair. |
| EER | EEPROM Fault | Internal non-volatile EEPROM memory read/write error | EEPROM failure, EEPROM data corruption due to sudden power loss during write | Attempt factory reset (C0002). If error cannot be cleared, internal EEPROM hardware failure — replace unit. |
| H05 | Hardware Fault | Internal control board component failure | Internal circuit board / micro-controller hardware malfunction | Internal hardware fault — return unit for service or replace controller. |
| CE0 | CAN System Bus Error | System bus CAN communication interruption / bus-off error | CAN line broken, incorrect terminating resistors (120 Ohm), baud rate mismatch | Check CAN bus wiring, shield connection, 120-ohm bus termination at both ends, and baud rate setting (C0351). |
| CE1 | Communication Module Error Slot A | Communication fault with fieldbus automation module in Slot A | Fieldbus cable disconnected, option module improperly seated or defective | Check fieldbus cable and master PLC status; re-seat or replace communication module. |
| P12 | Positioning Error / Following Error | Positioning tracking error / Schleppfehler exceeded allowed limit | Mechanical jamming, excessive load, acceleration too high, gain setting too low | Check axis mechanics for freedom of movement; adjust position controller gain parameters; verify positioning tolerance settings. |
| P13 | Limit Switch Triggered | Hardware or software end limit switch reached during movement | Axis traveled beyond normal operating range, limit switch sensor active | Manually or jog-mode move axis out of limit switch region; check limit switch wiring and position configuration. |
Frequently Asked Questions
What is the rated power and output current of the Lenze EVS9325-EPV004?
The Lenze EVS9325-EPV004 has a rated power output of 5.5 kW, a continuous output current of 13 A, and a peak output current capacity of 19.5 A on a 3-phase supply of 320 to 528 V AC.
How do I transfer parameters from a failed drive to a replacement unit?
Parameters can be copied using the optional Keypad XT (EMZ9371BC) memory function or saved and loaded via a PC running Lenze Global Drive Control (GDC) software.
What fieldbus communication options are supported on this model?
In addition to its onboard CAN system bus (up to 500 kbit/s), the drive accepts expansion cards in Slot A, including the EMF2133IB PROFIBUS-DP card and the EMF2175IB CANopen/DeviceNet card.
What does a solid red TRIP LED indicate on the front panel?
A solid red TRIP LED indicates an active drive fault. The output stage is disabled, and the specific error code can be read using the Keypad XT display, GDC software, or internal diagnostic registers.
What causes an OC1 fault and how should it be handled?
An OC1 fault indicates a short circuit at the motor output terminals, cabling, or windings. If this code appears immediately upon powering on without a motor connected, the internal power module is damaged, requiring repair or drive replacement.
Take advantage of our exchange formula
A defective product does not have to be worthless. At ABC Industrial Parts, you can hand in defective products and immediately benefit from a discount on your new purchase. This is a smart way to save money while contributing to a circular economy.
Play it safe with our warranty conditions
Industrial plants prefer to keep running invariably, no matter what. Therefore, it is essential that you can rely on high-quality products and/or sustainable repairs. With our warranty conditions, you can count on certainty, whether you choose new, used or repaired products.
Data backup and recovery
Have you lost valuable parameters or data due to a malfunction while the manufacturer no longer provides support? At ABC Industrial Parts, we help you secure this data, both for common and specific products.
Specific firmware and hardware versions
If you are working with specific hardware or firmware versions that are no longer available from the manufacturer, ABC Industrial Parts is your partner. When making your enquiry, clearly state which versions you need, we will then look at the possibilities of supplying those versions, so that your installations continue to function optimally.
Disclaimer:
We are not an authorised distributor of Lenze.
Product photos are for illustration purposes only and may differ from the actual product delivered.
Some of the content on this page was created with the help of AI. While we strive to provide accurate and up-to-date information, errors may occur.