Lenze EVS9328-EP 9300 Series Servo Position Controller


Het item werd toegevoegd aan uw offerteaanvraag
Product Information
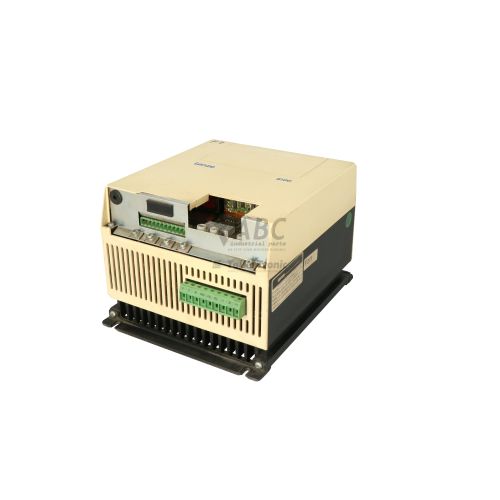
The Lenze EVS9328-EP is a 22 kW servo position controller from the 9300 Servo Drives family, engineered for precise multi-axis positioning, rotary table indexing, and high-dynamic servo motor drive applications. Operating on a 3-phase AC supply spanning 320 V AC to 528 V AC at 45 to 65 Hz with a rated input current of 45 A, this unit delivers a continuous output current of 47 A at an 8 kHz switching frequency and a peak output current of 70.5 A for up to 60 seconds. Designed with built-in positioning logic, the controller executes complex motion profiles directly within the drive stage, reducing computational overhead on host control systems. Thermal power dissipation is rated at 600 W under nominal loading.
For system integration, the EVS9328-EP features 8 digital inputs, 4 digital outputs, 2 analog inputs, and 2 analog outputs, along with an integrated CAN/CANopen system bus operating up to 500 kbit/s. A flexible Automation Interface (AIF) slot accepts optional communication modules such as the EMF2133IB or EMF2131IB PROFIBUS-DP cards, INTERBUS, or LECOM interfaces, as well as the EMZ9371BC operating keypad module. Feedback is managed through Sub-D connector X7 supporting standard 2-pole resolvers, alongside an X8 incremental encoder input and simulated encoder output. Commissioning a replacement unit requires restoring the exact drive parameter configuration, as the internal non-volatile EEPROM stores up to four independent parameter sets (PAR0 through PAR3). Parameters can be configured and uploaded using Lenze Global Drive Control (GDC) software versions 4.x or 5.x, EASY Starter platforms, or cloned directly via the EMZ9371BC keypad. Support from ABC Industrial Parts can assist in preparing replacement drives and transferring parameters to ensure seamless replacement.
System monitoring is provided via two front panel status LEDs: a Green Ready LED that remains solid when the drive is enabled and flashes when operation is inhibited, and a Red Fault LED that lights continuously on a TRIP error and flashes during warning conditions. Detailed fault diagnostics are accessible through parameter registers C0003 for active TRIP codes, register C0168 for the CANopen fault history buffer, and GDC diagnostic parameters C005x and C018x. Standard operational checks should verify 3-phase mains voltage, motor cable insulation, resolver connections at X7, and CAN bus termination resistors (120 Ohm). When internal hardware faults such as gate drive errors (PINT), memory corruption (EE/EER), or control board failures (H05) occur, field repair is not feasible, making a tested replacement unit or professional repair from ABC Industrial Parts the most reliable path to restore production.
Technical Specifications
| Rated power | 22 kW |
| Supply voltage range | 320 to 528 V AC |
| Rated input current | 45 A |
| Continuous output current | 47 A |
| Peak output current | 70.5 A |
| Switching frequency | 8 kHz |
| Power loss | 600 W |
| Digital inputs | 8 |
| Digital outputs | 4 |
| Analog inputs | 2 |
| Analog outputs | 2 |
| System bus interface | CAN / CANopen |
Programming and Configuration
The Lenze EVS9328-EP position controller integrates onboard positioning logic capable of handling complex point-to-point and profile motion commands directly within the drive. Motion parameters, target profiles, and axis speeds are managed through Lenze Global Drive Control (GDC) software versions 4.x or 5.x, or the EASY Starter configuration platform. When parameterizing positioning tasks, profile parameters and motion limits are assigned to ensure accurate target calculations and prevent position tracking errors.
Configuration data is stored in internal non-volatile EEPROM memory, which retains up to four independent, user-selectable parameter sets (PAR0 through PAR3). Drive behavior and active parameter sets can be switched dynamically or designated during commissioning. Parameter cloning and rapid field replacement are supported using the plug-in EMZ9371BC keypad module, allowing complete parameter sets to be transferred from a functional drive to a replacement unit without requiring a PC connection.
In instances where parameter structure corruption occurs or a complete reconfiguration is required, factory default settings can be restored by setting parameter C0002 to 1. Following a factory reset, the controller must be reloaded with the machine-specific parameter backup to re-establish feedback calibration, I/O mapping, and motion profile program logic.
Communication and System Integration
System bus integration on the EVS9328-EP is facilitated through the onboard CAN/CANopen interface at terminal block X4. Operating at transmission speeds up to 500 kbit/s, the CAN System Bus enables real-time inter-drive synchronization, multi-axis coordination, and high-speed data exchange with master controllers. Bus stability requires 120 Ohm termination resistors placed across the physical ends of the network line alongside proper cable shielding and grounding.
Extending fieldbus capability beyond the native CAN bus is accomplished using the integrated Automation Interface (AIF) slot. This expansion slot accommodates modular communication adapters, including the EMF2133IB and EMF2131IB PROFIBUS-DP cards, INTERBUS modules, and LECOM serial interface adapters. Selecting the appropriate AIF card enables seamless integration into established PLC networks without altering internal drive wiring.
Feedback and axis synchronization connectors include terminal X7, a Sub-D connector configured for standard 2-pole resolver feedback modules. Terminal X8 supports master frequency incremental encoder inputs as well as simulated encoder output signals, allowing master-slave drive synchronism and direct position feedback transmission to supervisory PLC systems.
Diagnostics and Status Indication
Operational status and fault conditions are signaled through front-panel LED indicators and diagnostic registers. The Green Ready LED indicates drive status, remaining lit continuously during normal operation when the inverter is enabled and flashing when drive operation is inhibited or running in a specific function block state. The Red Fault LED illuminates continuously when an active TRIP condition occurs, flashes during warning states, and remains unlit under normal operating conditions.
Detailed troubleshooting is supported via the EMZ9371BC operating keypad, which displays specific fault codes from the C0003 TRIP fault register. Additional diagnostic monitoring and real-time oscilloscope functions are available through GDC parameters C005x and C018x. Network and fault history buffers are retained in CANopen register C0168 to assist technicians in analyzing intermittent faults.
Status LED Indicators
| LED | Color/Status | Meaning |
|---|---|---|
| Ready (Green LED) | Green - Solid / Flashing | Continuous ON indicates drive is operational and ready/enabled. Blinking indicates drive operation disabled or running in specific function block state. |
| Fault (Red LED) | Red - Solid / Flashing / Off | Continuous ON indicates active TRIP error condition. Blinking indicates active WARNING message. OFF indicates normal operational condition. |
Replacement and Spare Part Considerations
When replacing a Lenze EVS9328-EP servo position controller, ensure the spare unit matches the exact part number and 22 kW power rating. Installing a unit with different firmware or power specifications can result in feedback scaling mismatches, overcurrent faults, or communication failures on the host bus network.
Before connecting power to a new drive, transfer the plugged AIF automation module (such as PROFIBUS EMF2133IB/EMF2131IB) from the failed unit to the replacement slot. Verify that the parameter set stored in the replacement drive aligns with the machine configuration by uploading the parameter backup via GDC software or transferring the configuration using an EMZ9371BC keypad module.
Physical replacement procedures require checking the 3-phase AC input supply voltage on lines L1, L2, and L3, inspecting motor phase cables for insulation breakdown, and ensuring resolver coupling integrity at connector X7. If the original unit failed due to internal hardware faults like PINT or H05, complete line and motor insulation checks prior to powering up the spare controller.
Error Codes & Fault Codes
The following error codes may be displayed during operation or diagnostics:
| Code | Name | Description | Possible Cause | Recommended Action |
|---|---|---|---|---|
| OC1 | Short circuit | Short circuit detected on motor output phase lines or power transistor bridge. | Short circuit in motor cable or motor winding; earth fault; shorted power semiconductor in drive. | Check motor cable and motor windings for short circuits or insulation breakdown. If fault occurs instantly with power connection detached, power section is defective and unit requires service/replacement. |
| OC2 | Earth fault | Ground fault / earth current leakage detected on motor output. | Ground connection or insulation fault in motor phases, motor leads, or brake resistor wiring. | Inspect motor cables and motor stator windings with insulation tester. Replace damaged motor cable or repair insulation. |
| OC5 | I x t overload | Drive output thermal overload protection triggered due to sustained overcurrent. | Excessive mechanical load, mechanical jam, accelerated duty cycle beyond drive rated continuous capacity. | Check drive sizing, reduce acceleration rates, resolve mechanical binding in driven axis. |
| OU | Overvoltage DC bus | DC bus voltage exceeded maximum allowable threshold limit. | Excessive regenerative energy during deceleration; brake chopper inactive; open circuit or defective brake resistor; line supply voltage too high. | Verify mains supply voltage; check external brake resistor resistance and thermal switch wiring; increase deceleration time ramp. |
| LU | Undervoltage DC bus | DC link voltage dropped below minimum threshold limit. | Mains supply failure; phase loss; mains input voltage too low; charging circuit resistor defect. | Check 3-phase mains voltage and fuses. If mains supply is correct, internal DC link voltage detection circuit is faulty and requires unit replacement. |
| OH | Heat sink overtemperature | Drive heatsink temperature exceeded maximum operating limit. | Insufficient cooling airflow; fan defect; clogged heat sink fins; high cabinet ambient temperature. | Clean heat sink cooling fins, check operation of internal/external cooling fans, improve control cabinet ventilation. |
| OH4 | Motor overtemperature | Thermal sensor input (PTC / KTY) reported excessive motor temperature. | Motor thermal overload; mechanical binding; thermal sensor disconnected or open circuit. | Allow motor to cool down; inspect motor cooling fan; check wiring to sensor input on terminal block. |
| OH7 | Interior overtemperature | Internal air temperature inside drive enclosure exceeded maximum limit. | Control enclosure ambient temperature too high; internal fan failure. | Reduce control cabinet ambient temperature; ensure free space above and below drive. |
| CE0 | AIF communication error | Communication failure between drive control board and plug-in AIF automation module. | AIF fieldbus module loose, disconnected, or defective; fieldbus network cable damaged; fieldbus master stopped. | Verify module seating in AIF slot; check communication cables and master controller operation; replace AIF module. |
| CE1 | CAN System Bus error 1 | Bus-off error or telegram timeout on integrated CAN System Bus (X4). | Incorrect bus baud rate; missing bus termination resistors (120 Ohm); broken CAN wiring; interference/shielding issue. | Verify CAN wiring, termination resistors at both ends of bus, baud rate configuration, and grounding/shielding. |
| EE | EEPROM error | Checksum fault or corruption detected in internal parameter memory. | Power failure during parameter store operation; internal memory chip defect. | Reload factory default parameters (C0002 = 1) and reload parameters from backup. If fault persists, internal control board failure — return unit for repair or replace unit. |
| EER | EEPROM read error | Internal EEPROM data read error on initialization. | Internal control board hardware failure. | Internal hardware fault — return unit for repair or replace drive. |
| H05 | Internal hardware error | Internal controller card / DSP board failure detected during self-test. | Control board hardware failure or corrupted internal firmware. | Internal hardware fault — return unit for repair or replace drive. |
| NMAX | Speed threshold exceeded | Actual motor speed exceeded maximum configured speed limit (C0011). | Overhauling load; incorrect speed controller tuning; feedback encoder / resolver slipping or damaged. | Check motor encoder/resolver mechanical coupling; re-tune speed controller loop; adjust C0011 limit if valid. |
| PINT | Power section fault | Fault reported by internal power module driver or gate drive circuit. | Internal power transistor driver failure or power supply module error. | Internal hardware fault in power section — unit requires repair or replacement. |
| PR0 | Positioning profile program error 0 | Target position calculation error or invalid program parameter in positioning task. | Out-of-bounds target position parameter; invalid move profile command. | Check position target values and motion profile program logic in GDC / PLC software. |
| PR1 | Positioning tracking error | Following error exceeded defined maximum limit during positioning movement. | Mechanical obstacle or binding; gain settings too low; acceleration too aggressive for motor capacity. | Inspect mechanical motion axis for obstruction; verify drive sizing and position loop gain parameters. |
| PS | Parameter set error | Inconsistent parameter set selected or corrupted parameter structure. | Attempting to switch to an unconfigured parameter set; parameter corruption. | Verify configured parameter sets PAR0...PAR3; reload parameter configuration into drive. |
| Sd1 | Resolver fault | Resolver signal loss or tracking fault detected on X7 feedback connector. | Defective resolver cable, loose connector pin, or failed resolver feedback sensor. | Check Sub-D connector X7 connection, cable shield grounding, and resolver winding resistance. |
| Sd2 | Encoder track fault | Encoder pulse loss or channel A/B phase fault on encoder input X8. | Damaged incremental encoder, broken encoder wiring, supply voltage drop on encoder line. | Inspect encoder wiring on X8 connector; test encoder signal levels with oscilloscope; replace encoder if necessary. |
| LP | Line phase failure | Phase loss detected on AC mains input lines L1, L2, or L3. | Blown mains input fuse, tripped circuit breaker, or loose line conductor. | Check AC input voltages on terminals L1, L2, L3 and replace blown mains line fuses. |
Frequently Asked Questions
Which programming software is required to configure the Lenze EVS9328-EP?
The Lenze EVS9328-EP is parameterized and configured using Lenze Global Drive Control (GDC) software versions 4.x or 5.x, or the EASY Starter platform. Alternatively, basic parameter adjustments and cloning can be performed via the EMZ9371BC keypad module.
How are parameter sets backed up and transferred to a spare unit?
The drive stores four parameter sets (PAR0 through PAR3) in internal non-volatile EEPROM. Parameters can be backed up to a PC running GDC software or cloned directly onto an EMZ9371BC keypad module, which can then be plugged into the replacement drive to download the configuration.
What does an OC1 fault code indicate on the EVS9328-EP?
An OC1 fault indicates a short circuit on the motor output phase lines or within the power transistor bridge. Check motor cables and motor windings for insulation failure. If OC1 triggers instantly upon power connection with motor leads disconnected, the internal power section is defective.
Which communication protocols are supported via the AIF expansion slot?
The Automation Interface (AIF) slot supports fieldbus modules including PROFIBUS-DP (EMF2133IB and EMF2131IB), INTERBUS, and LECOM serial communication adapters, in addition to the EMZ9371BC operating keypad.
What steps should be taken if an EE or EER fault code appears?
EE and EER indicate parameter memory checksum faults or read errors. Attempt to clear the error by resetting the drive to factory defaults (setting parameter C0002 = 1) and restoring the parameter set from a backup. If the fault persists, internal control hardware has failed and the unit requires repair or replacement.
Take advantage of our exchange formula
A defective product does not have to be worthless. At ABC Industrial Parts, you can hand in defective products and immediately benefit from a discount on your new purchase. This is a smart way to save money while contributing to a circular economy.
Play it safe with our warranty conditions
Industrial plants prefer to keep running invariably, no matter what. Therefore, it is essential that you can rely on high-quality products and/or sustainable repairs. With our warranty conditions, you can count on certainty, whether you choose new, used or repaired products.
Data backup and recovery
Have you lost valuable parameters or data due to a malfunction while the manufacturer no longer provides support? At ABC Industrial Parts, we help you secure this data, both for common and specific products.
Specific firmware and hardware versions
If you are working with specific hardware or firmware versions that are no longer available from the manufacturer, ABC Industrial Parts is your partner. When making your enquiry, clearly state which versions you need, we will then look at the possibilities of supplying those versions, so that your installations continue to function optimally.
Disclaimer:
We are not an authorised distributor of Lenze.
Product photos are for illustration purposes only and may differ from the actual product delivered.
Some of the content on this page was created with the help of AI. While we strive to provide accurate and up-to-date information, errors may occur.